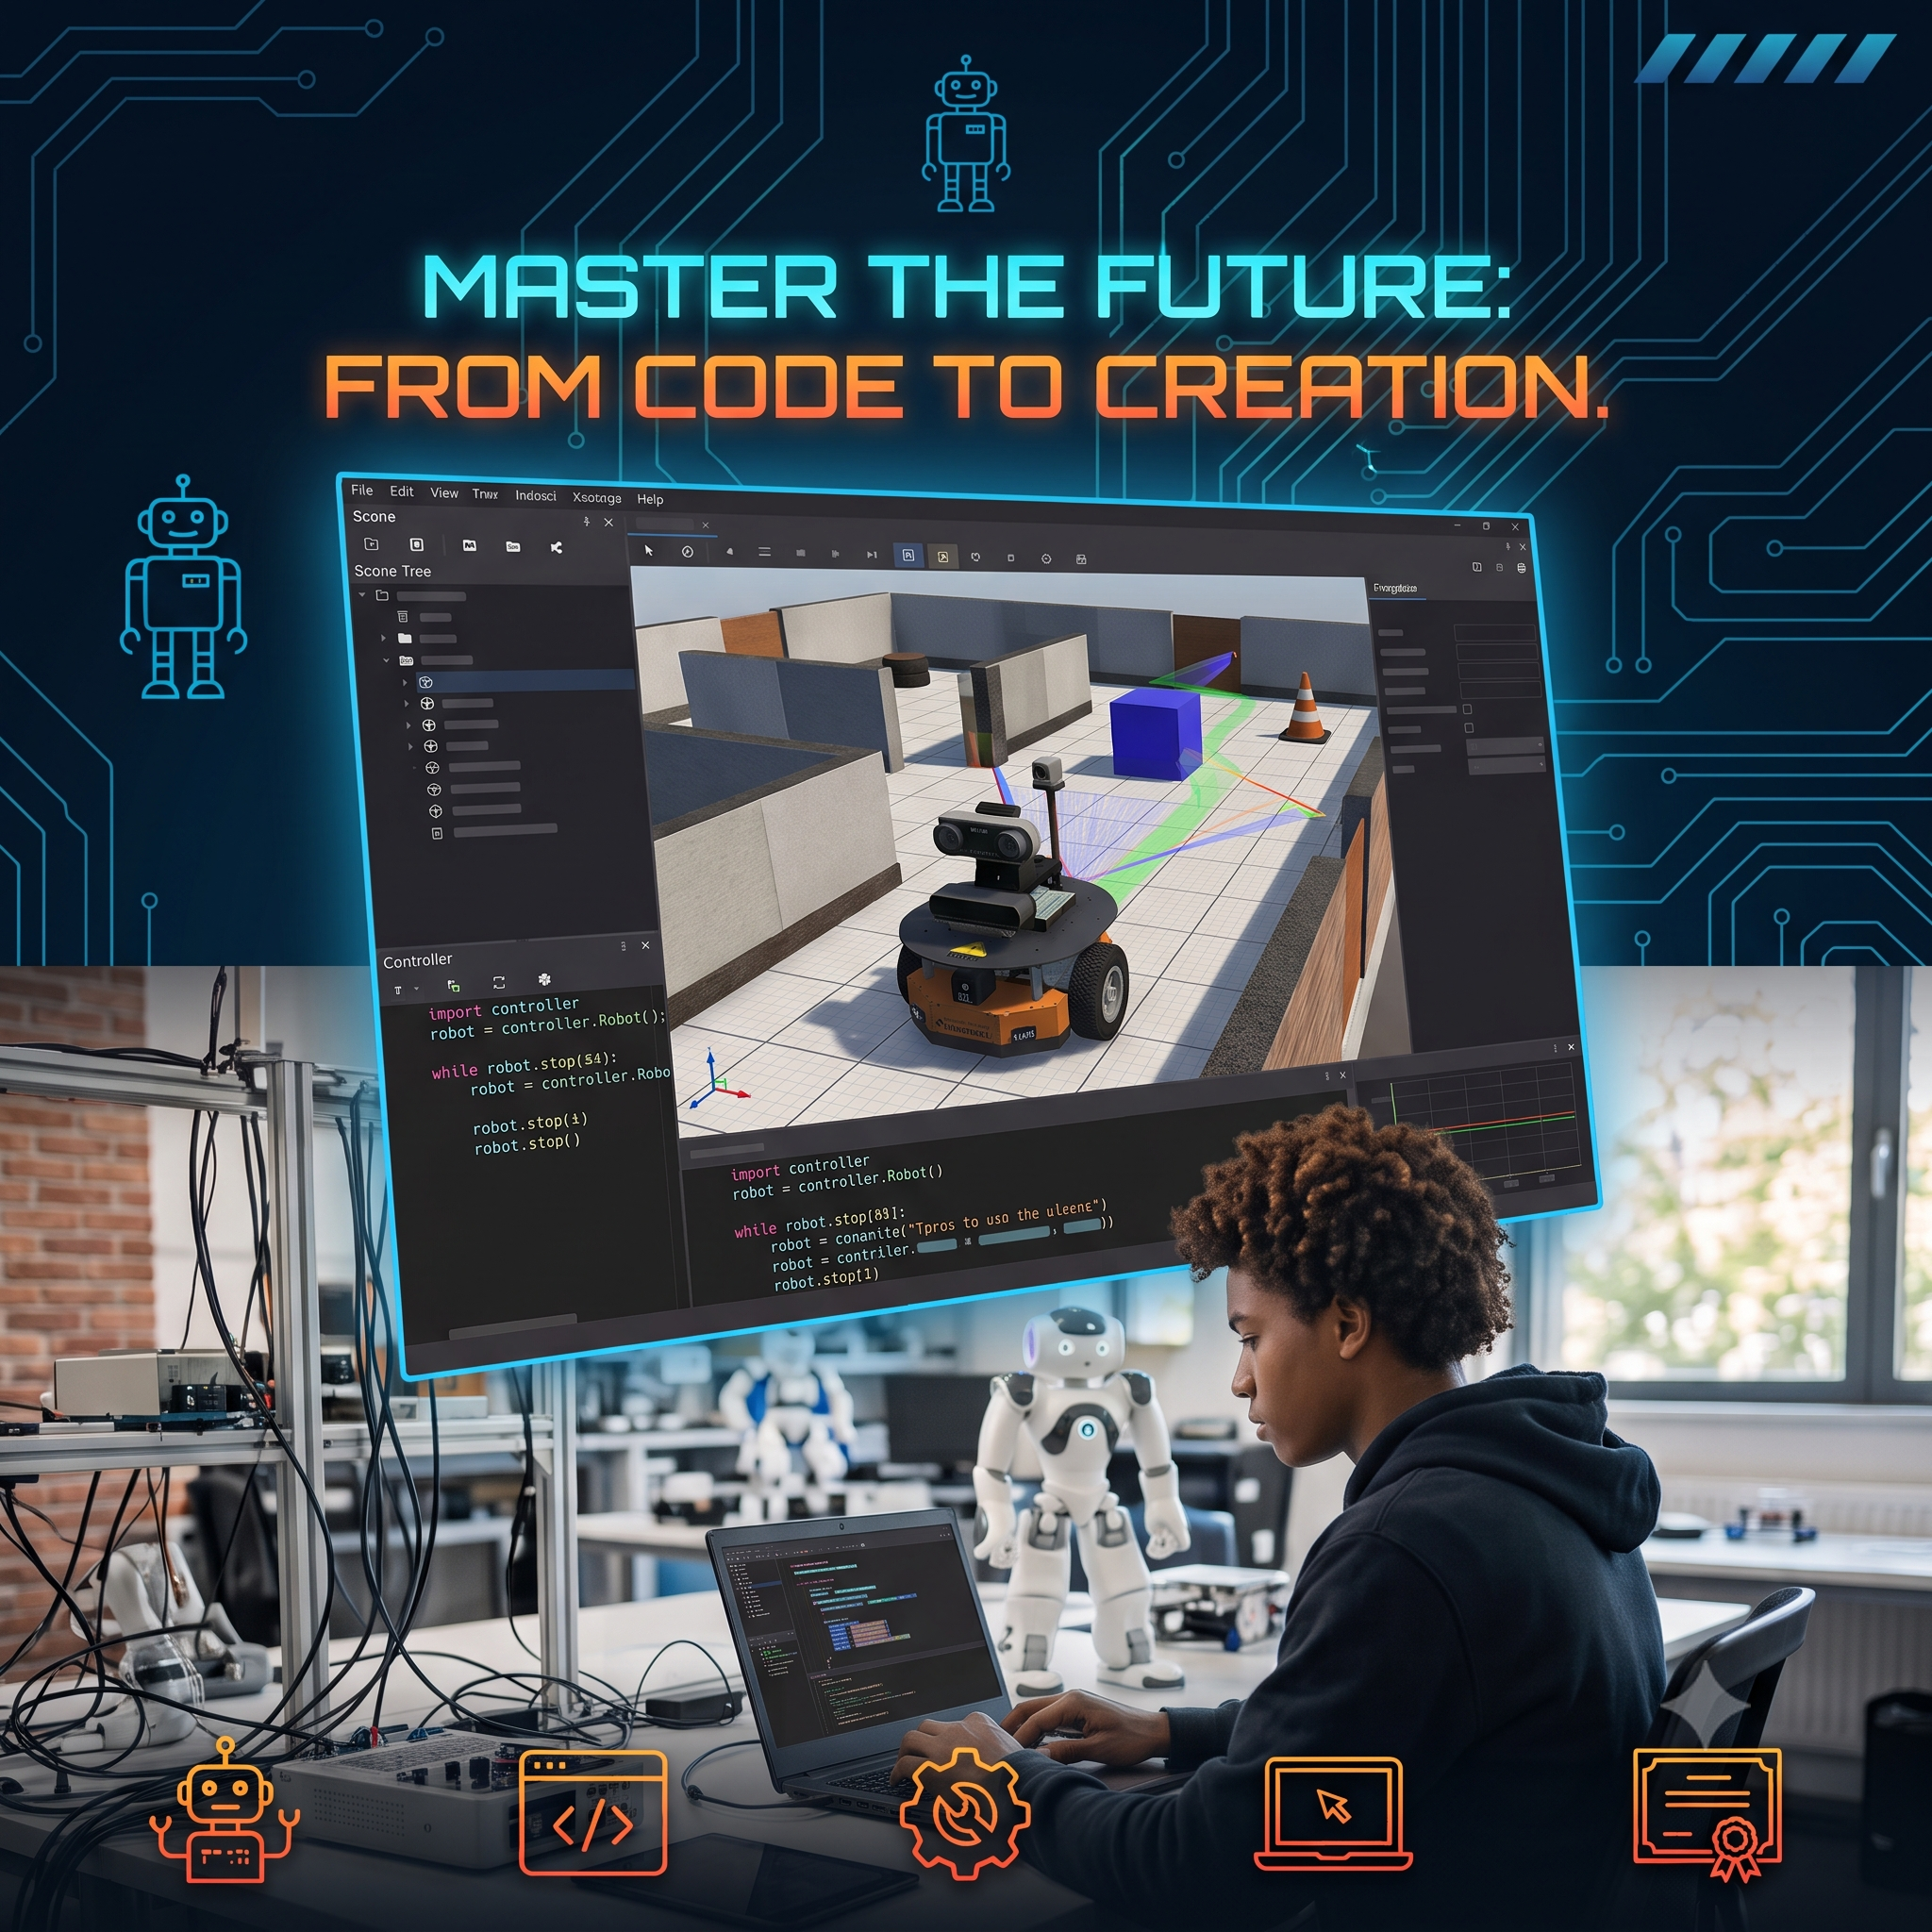
A beginner course on the open-source 3D robot simulator. Build a world, load the e-puck robot, and write Python controllers for obstacle avoidance and line following before touching real hardware.
Created by Kasuadana Adams
11 sections • 3 lessons • 1h total
Purchase everything you need for this project directly
₵0.00
Total for required items
A beginner course on the open-source 3D robot simulator. Build a world, load the e-puck robot, and write Python controllers for obstacle avoidance and line following before touching real hardware.
Hardware prototyping usually means dealing with broken parts, dead batteries, and endless waiting. Webots replaces that headache with a free 3D sandbox where you can iterate as much as you want before moving your code to real metal.
Starting completely from scratch, you will use Python to program two practical behaviors on the e-puck robot: wall avoidance and line tracking. Everything runs inside the software, so you can focus entirely on learning the logic without managing physical electronics.